Generalization trials: 28 runs across 4 objects
This page exists so that every success rate we quote can be traced: to a specific run, to what was on the table at the time, and to a video of it. The organiser warned explicitly against unsupported success-rate claims.
· Same object (the yellow cup, present in the training data): 9/10 = 90%
· Objects never seen in training (blue cup / blue can / red can) combined: 8/12 = 67%
Always state them as "n of m".
The four objects
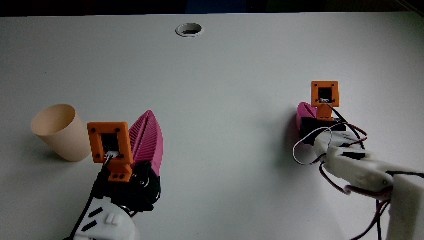
in the training data
9/10 = 90% (13 runs, 3 void)
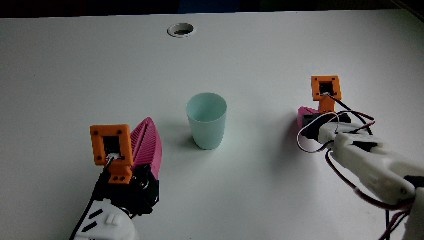
never seen in training
2/3 = 67% (5 runs, 2 void)
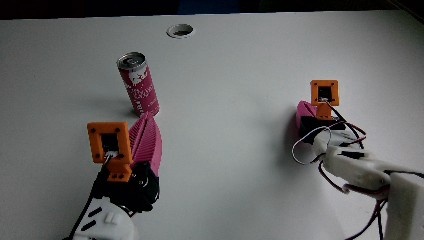
unseen · different material
3/5 = 60% (6 runs, 1 void)
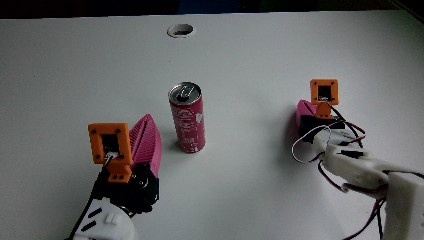
unseen · different material and colour
3/4 = 75% (4 runs, 0 void)
| Object | Note | Runs | Success | Failure | Void | Rate |
|---|---|---|---|---|---|---|
| Yellow cup | in the training data | 13 | 9 | 1 | 3 | 90% |
| Blue cup | never seen in training | 5 | 2 | 1 | 2 | 67% |
| Blue can | unseen · different material | 6 | 3 | 2 | 1 | 60% |
| Red can | unseen · different material and colour | 4 | 3 | 1 | 0 | 75% |
| Total | 28 | 17 | 5 | 6 | 77% | |
How the rate is defined: the denominator excludes void runs — a void is a run discarded for reasons outside the model (an interrupted operation, for instance) and is not counted for or against it. Including voids the overall figure is 17/28 = 61%.
Autonomous footage — not teleop, not replay
Cut to 1:47 for the two-minute technical demo slot, in three parts:
① 11 grasps at 4× speed — for each object, the 2–3 successes with the widest positional
separation; each clip is labelled with the object, that object's success rate, and where the cup
actually was;
② a 1 → 9 → 16 → 25 grid montage, each tile one real grasp closing, bordered by object colour;
③ the position distribution chart (same image as below).
All source material comes from 05-training/trials/videos/ and keyframes/, with
no cosmetic editing.
Where each grasp closed
Every point is the position at which one grasp actually closed, computed by forward kinematics from that frame's joint angles. Colour and shape both encode the object (dual encoding, so it survives colour-blindness); filled = success, hollow = failure, grey = void.
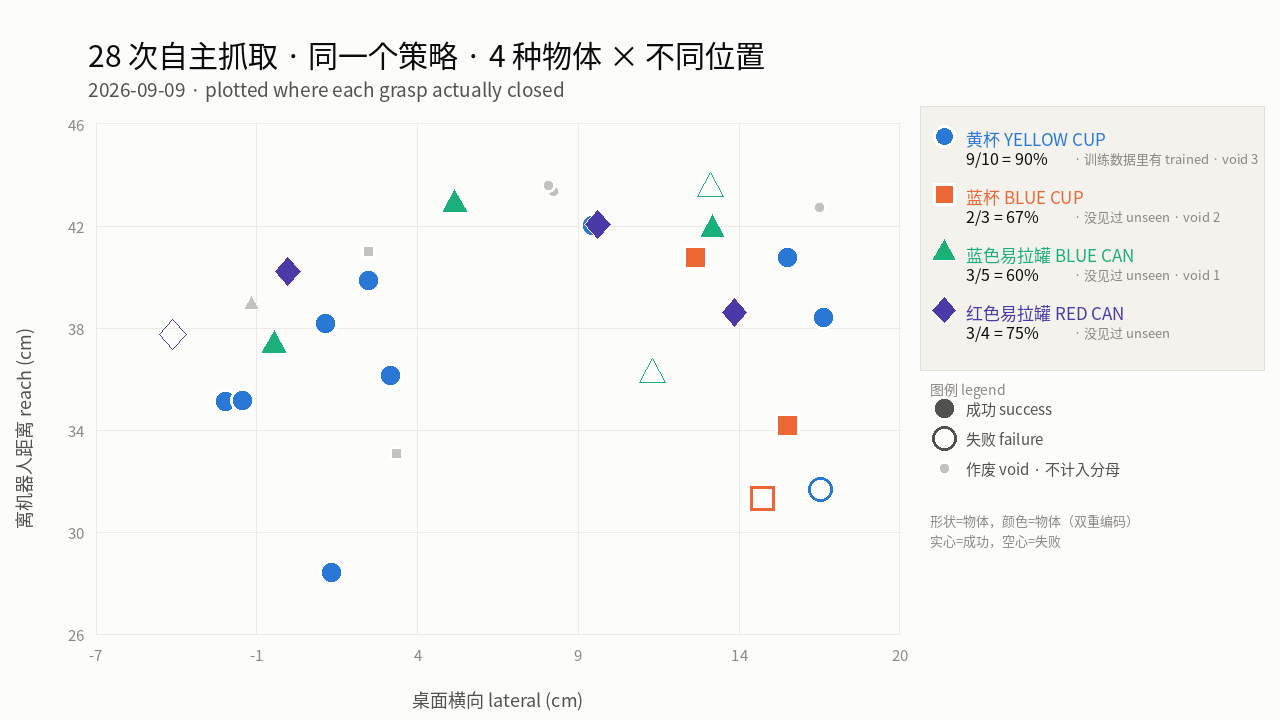
About 24 cm of lateral spread and 15 cm of reach. This chart is the direct evidence of generalization — one policy, four objects, all at different places.
· Every run has its own
trace file holding two sequences — the policy's raw output and
the safety-filtered command. A replay has no policy output at all;· The trial record carries
counts{OK/CLIPPED/HELD}, the safety layer's per-frame
intervention tally. The teleop path does not produce it;· The same model reaches 67% on three objects that never appear in the training data. A replay cannot do that.
Run by run
All 28 in chronological order. Object identification by the operator who was present.
| # | Batch | Object | Outcome | Video |
|---|---|---|---|---|
| 1 | 170405 t1 | Yellow cup | success | yes |
| 2 | 170405 t2 | Yellow cup | success | yes |
| 3 | 171624 t1 | Yellow cup | success | yes |
| 4 | 172016 t1 | Yellow cup | success | yes |
| 5 | 172016 t2 | Yellow cup | success | yes |
| 6 | 172016 t3 | Yellow cup | success | yes |
| 7 | 172016 t4 | Yellow cup | void | yes |
| 8 | 172016 t5 | Yellow cup | success | yes |
| 9 | 172016 t6 | Yellow cup | void | yes |
| 10 | 172016 t7 | Yellow cup | void | yes |
| 11 | 172016 t8 | Yellow cup | failure | yes |
| 12 | 172016 t9 | Yellow cup | success | yes |
| 13 | 172016 t10 | Yellow cup | success | yes |
| 14 | 174614 t1 | Blue cup | failure | yes |
| 15 | 174614 t2 | Blue cup | success | yes |
| 16 | 175304 t1 | Blue cup | void | yes |
| 17 | 175304 t2 | Blue cup | success | yes |
| 18 | 175304 t3 | Blue cup | void | yes |
| 19 | 175304 t4 | Blue can | failure | yes |
| 20 | 180807 t1 | Blue can | success | yes |
| 21 | 180807 t2 | Blue can | success | yes |
| 22 | 180807 t3 | Blue can | void | yes |
| 23 | 180807 t4 | Blue can | failure | yes |
| 24 | 180807 t5 | Blue can | success | yes |
| 25 | 182715 t1 | Red can | success | yes |
| 26 | 182715 t2 | Red can | success | yes |
| 27 | 182715 t3 | Red can | failure | yes |
| 28 | 182715 t4 | Red can | success | yes |
Where the raw material lives
| Content | Path |
|---|---|
| Trial records (incl. per-frame safety statistics) | 05-training/trials/trials-20260909-*.json |
| Keyframes (init / closure / end) | 05-training/trials/keyframes/ |
| Per-run video | 05-training/trials/videos/ |
| Policy raw output vs safety-filtered output | 05-training/trials/traces/*.npz |
| Model | xlerobot-smolvla-left-sd-p0.2-b16-u20000 / checkpoint 020000 |
| Training dataset | xlerobot-team/xlerobot-left-pick-cup-sep3-clean-20260905 |
Start frame of all 28 runs
If a juror wants to check what was on the table each time, this one image covers it. Labels read "batch t-number [S success / F failure / V void]".

target_object field would turn this kind
of check into a query.
xlerobot-smolvla-left-sd-p0.2-b16-u20000 · trials dated 2026-09-09 ·
object labelling by the on-site operator, 2026-09-10 · per-run outcomes taken directly from the trial
records with no manual adjustmentThis page uses system fonts only and makes no external requests.